CoRL 2026
RPL: Learning Robust Humanoid Perceptive Locomotion over Challenging Terrains
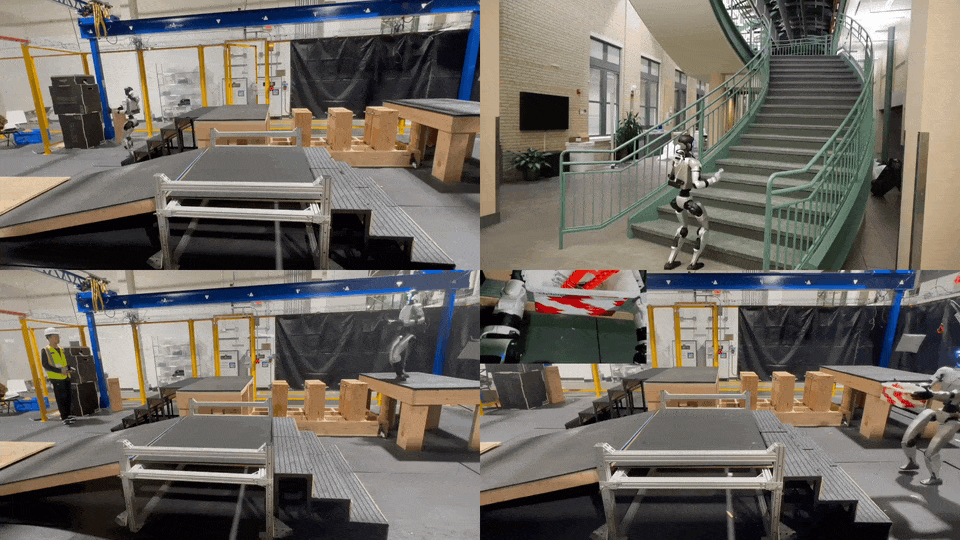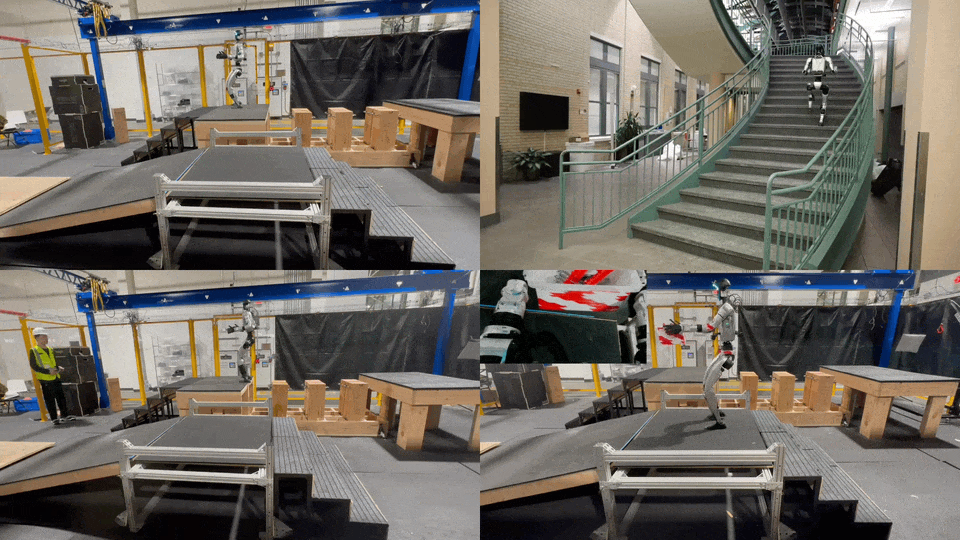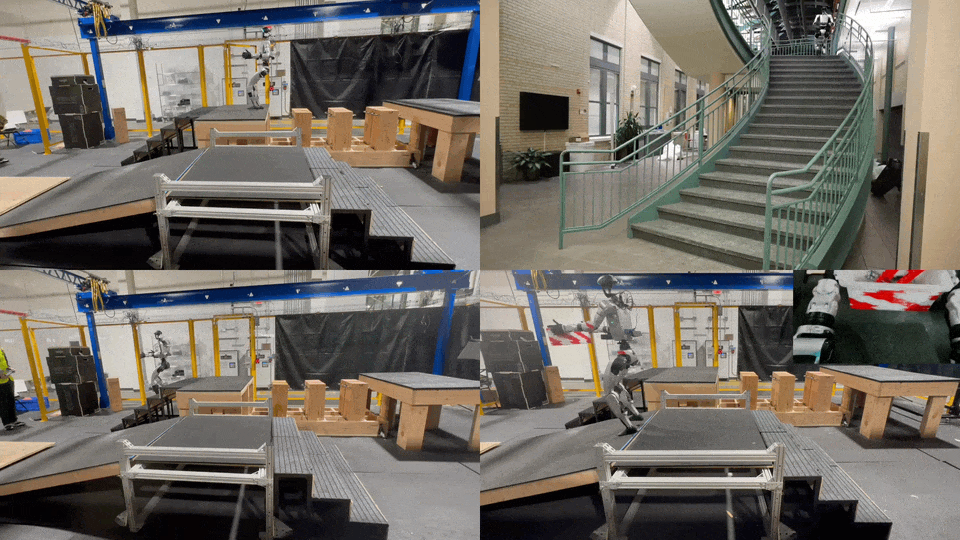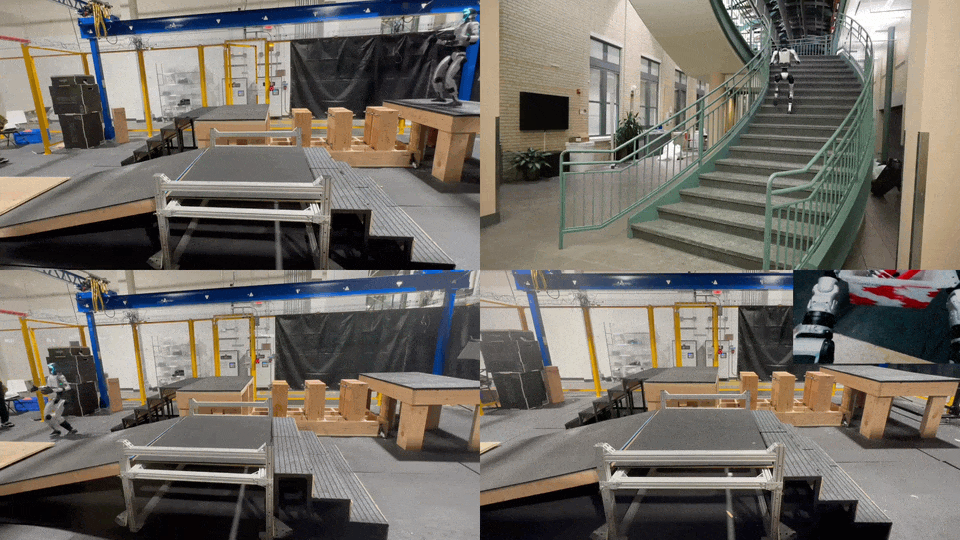
A unified multi-depth policy for humanoid locomotion across slopes, stairs, and stepping stones, with varied movement directions and payloads.
Solution Architect, RoboticsNVIDIA
I’m a solution architect at NVIDIA working on Physical AI & Robotics. I help bring NVIDIA’s advanced robotics technologies into real-world applications.
I received my master’s degree from Carnegie Mellon University’s Robotics Institute, where I worked on robot learning and humanoid systems.
I’m always happy to connect, exchange ideas, or grab a coffee. Feel free to reach out!
CoRL 2026
A unified multi-depth policy for humanoid locomotion across slopes, stairs, and stepping stones, with varied movement directions and payloads.
RSS 2026
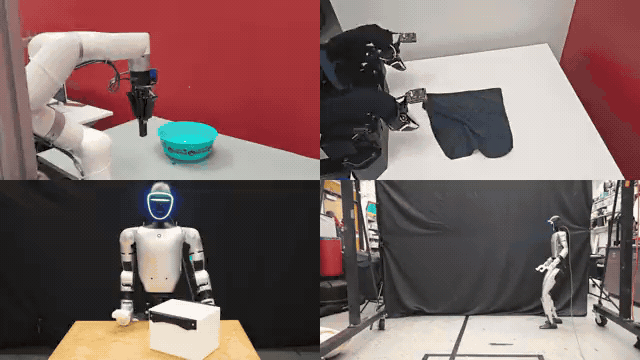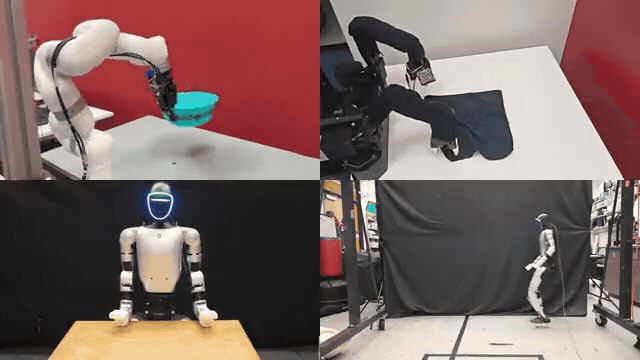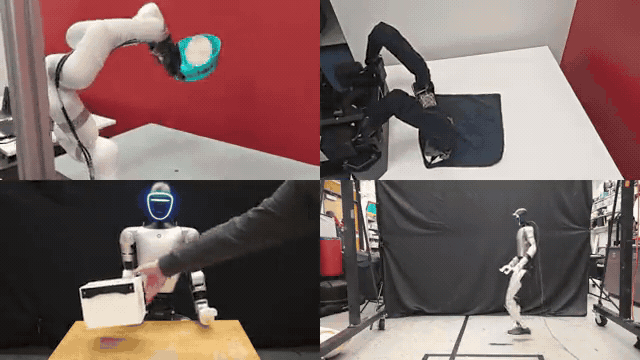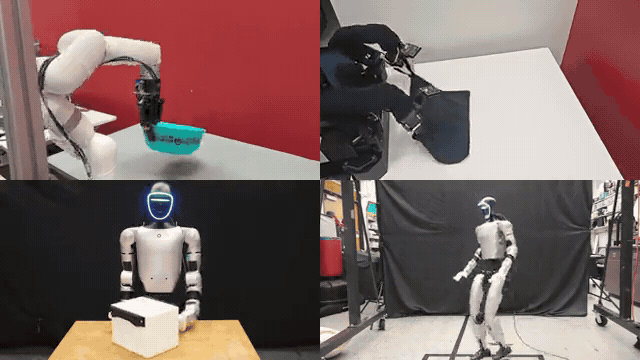
An open-source Python library with a unified interface for robot control, teleoperation, data collection, and policy deployment across embodiments.
L4DC 2026 · Oral
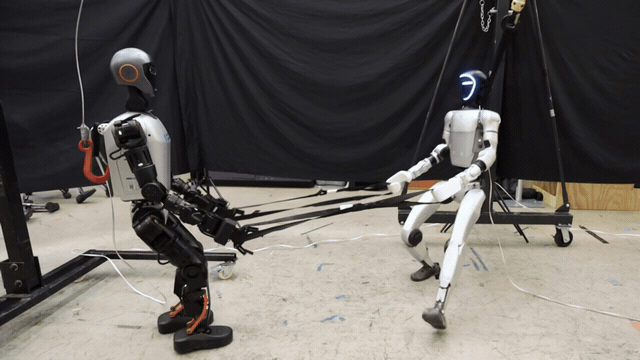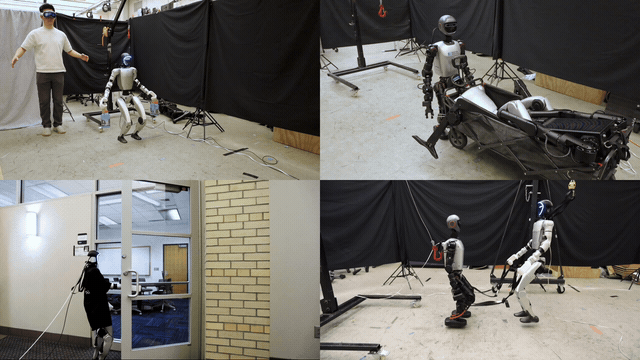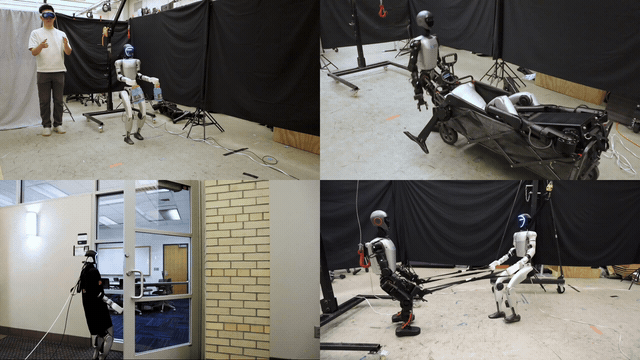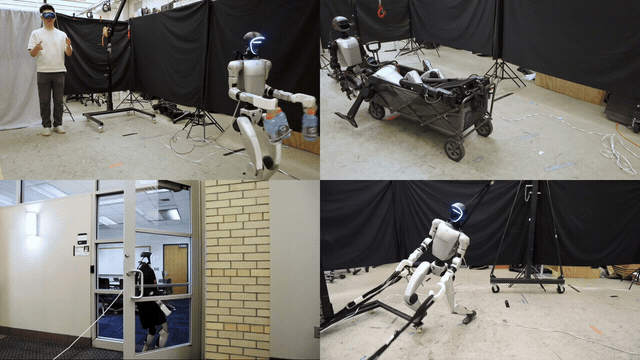
A dual-agent, force-adaptive reinforcement learning framework for heavy-duty humanoid loco-manipulation tasks.
CMU MRSD capstone 2025
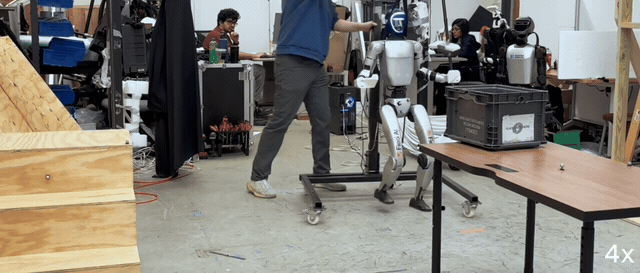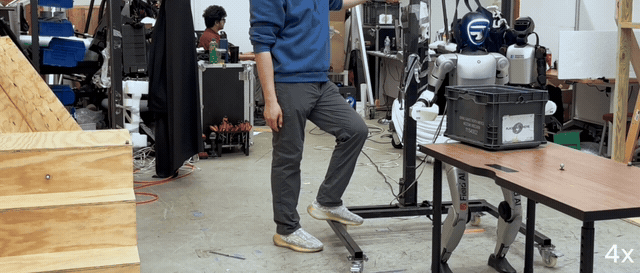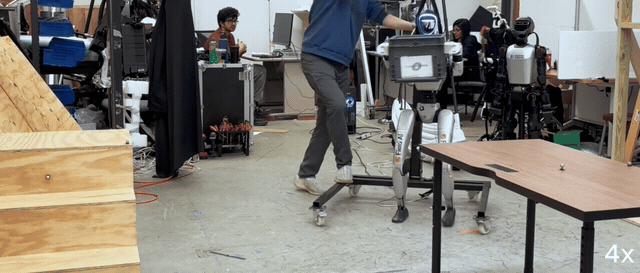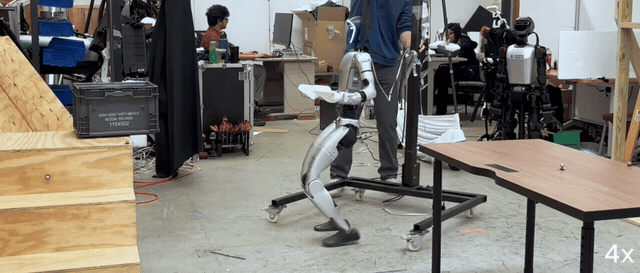
Built perception and autonomy for tote logistics on the Unitree G1, then developed VLA-based manipulation with GR00T, asynchronous inference, and teleoperation infrastructure.
Advised by Guanya Shi · Sponsored by Nissan & Field AI
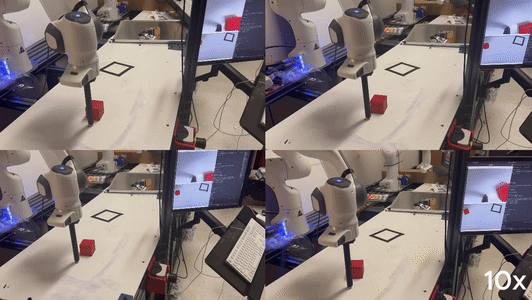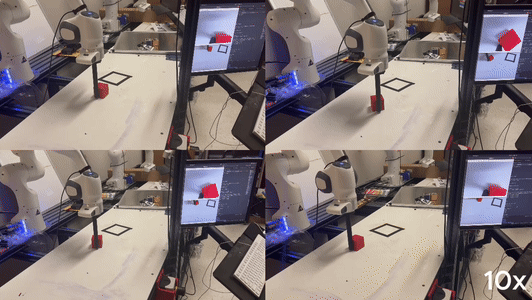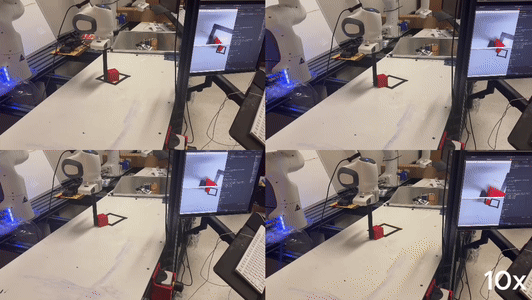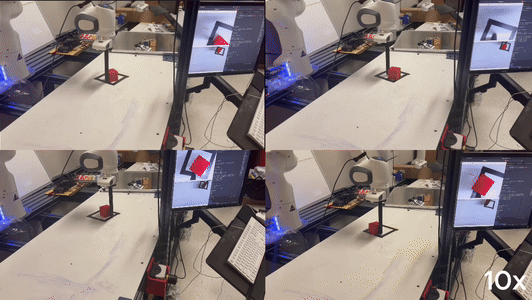
CMU course project 2025
Trained and deployed a manipulation policy using RGB-D and robot state inputs on a Franka Panda. Collected demonstrations with a MoveIt-based controller and human-in-the-loop guidance.
WPI capstone 2024
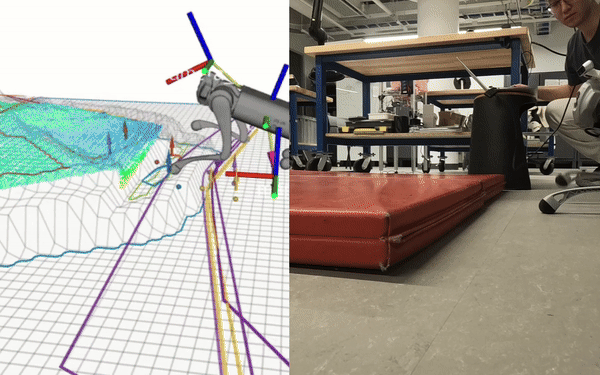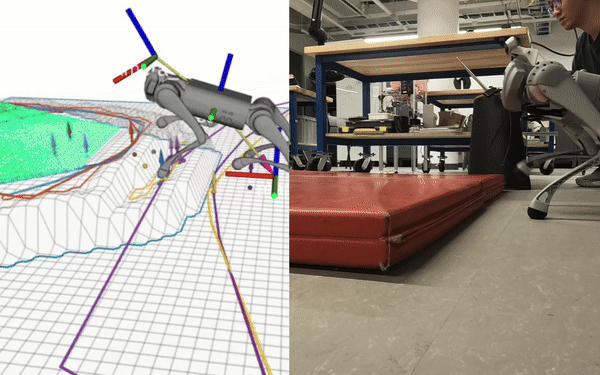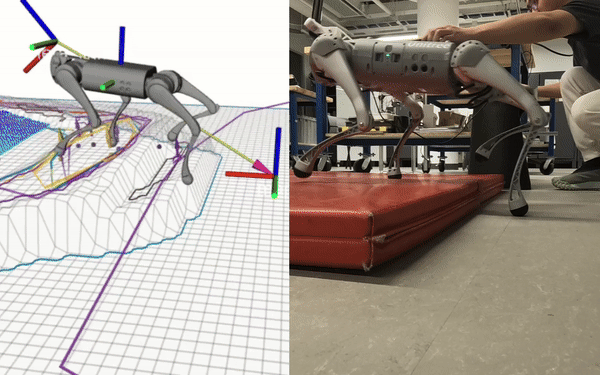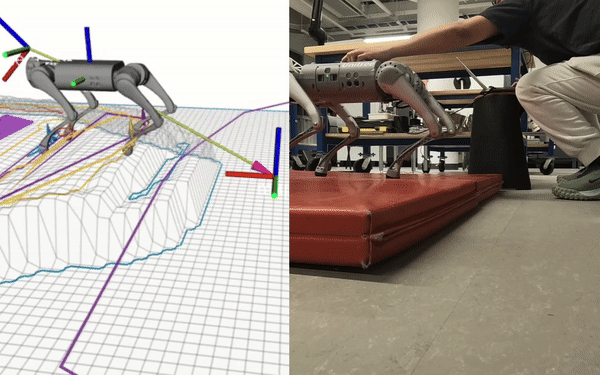
Combined real-time terrain mapping, nonlinear model predictive control, and whole-body control to help a Unitree Go1 navigate challenging, uneven surfaces.
Advised by Mahdi Agheli · ALMaS Group
WPI Research Project 2024
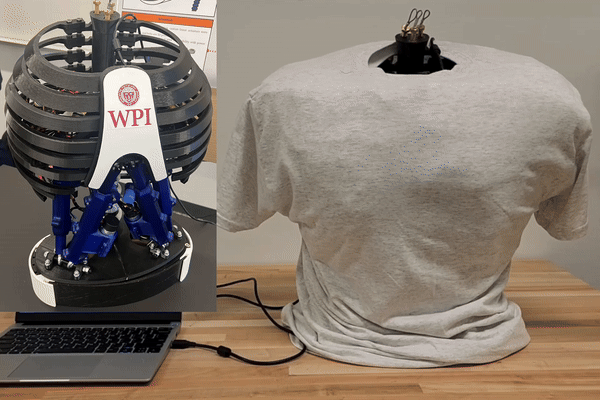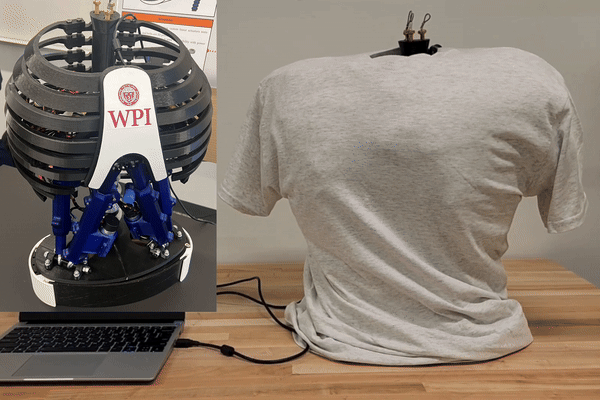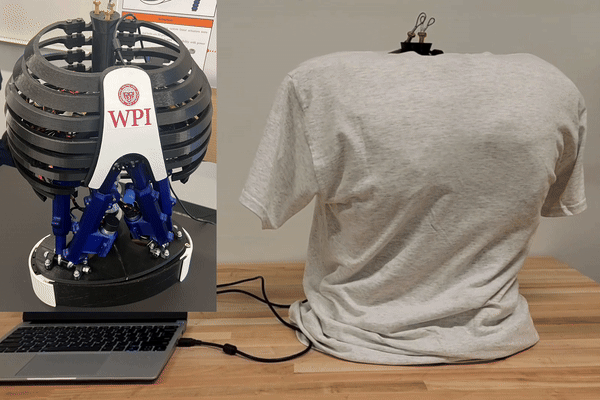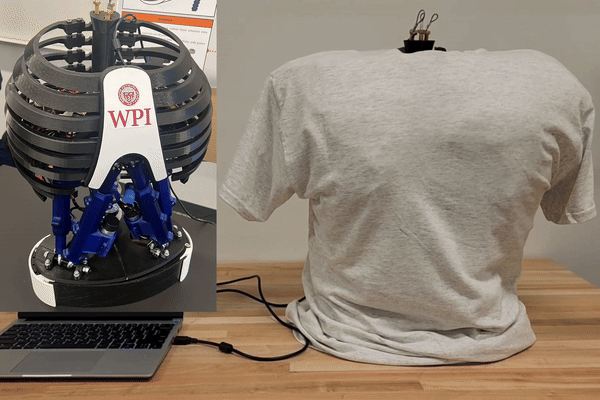
Designed a compliant robot torso with 3D-printed TPU discs and a parallel-manipulator actuation system for three-degree-of-freedom rotation.
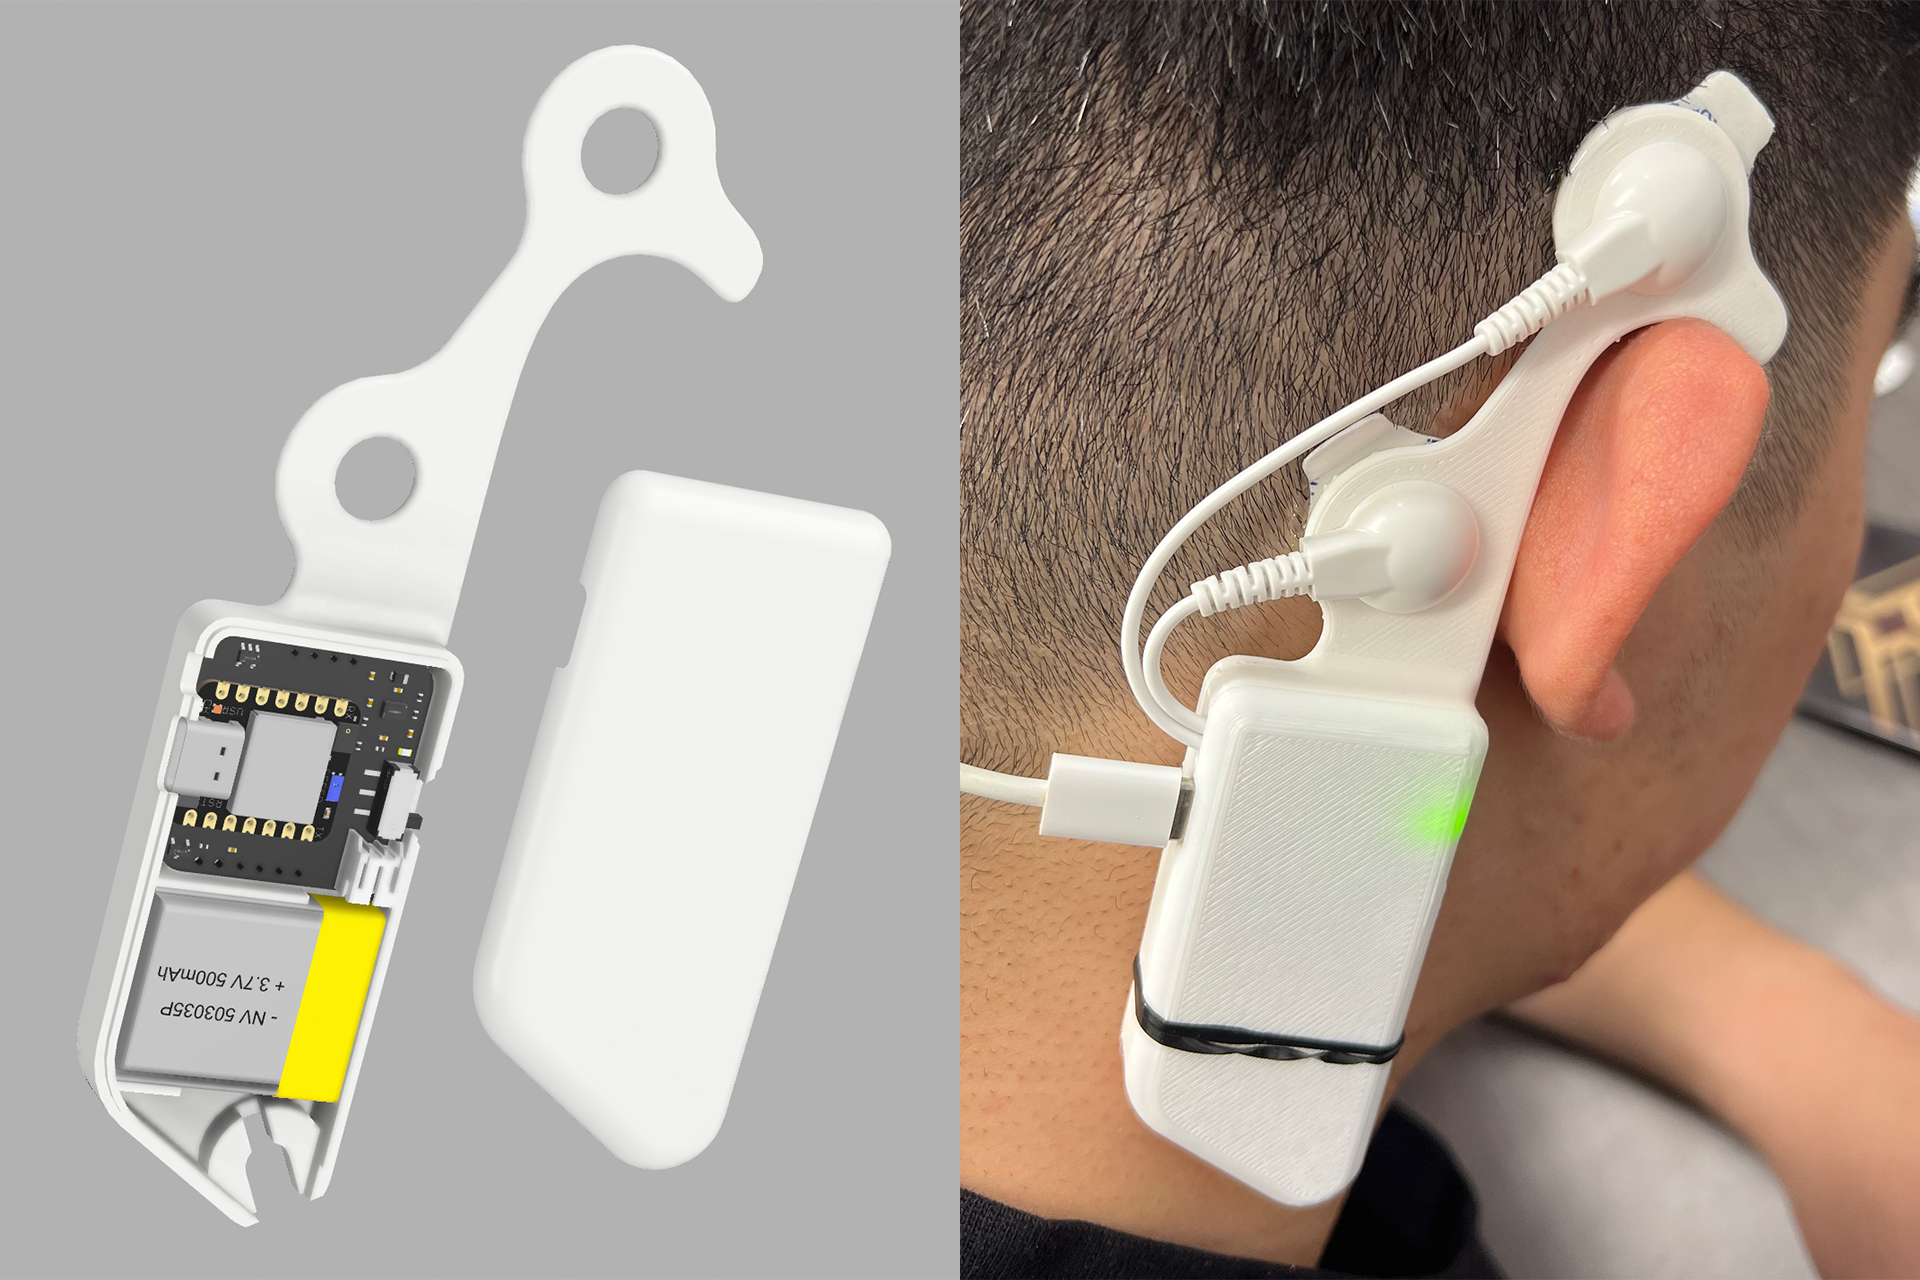
WPI Research Project 2024
Built a portable single-channel EEG device with a custom Bluetooth-enabled PCB and 3D-printed enclosure for closed-loop audio stimulation and overnight sleep recording.
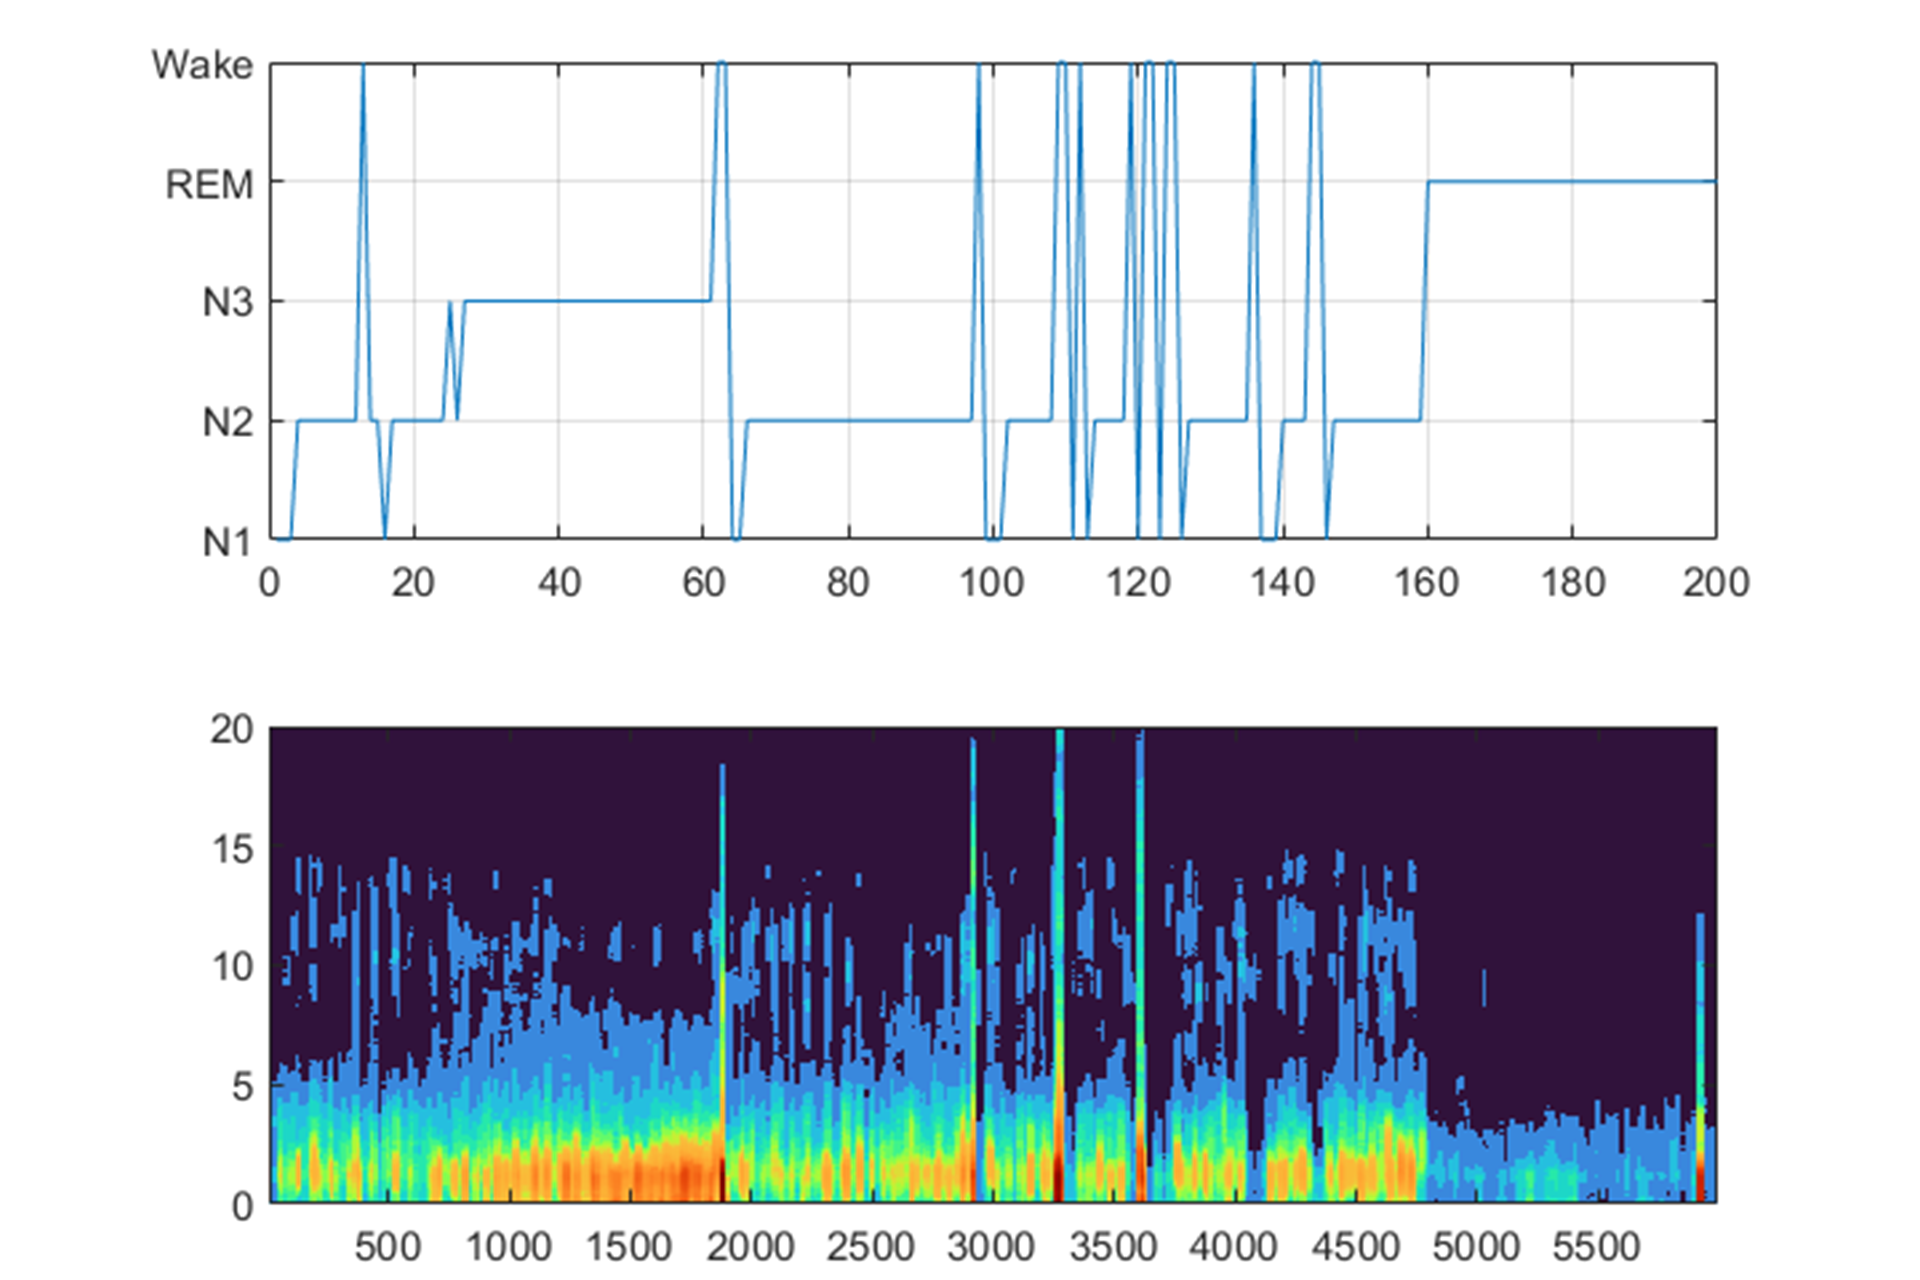
WPI Research Project 2024
Developed a deep learning model that extracts time-invariant features from raw single-channel EEG for sleep-stage scoring.
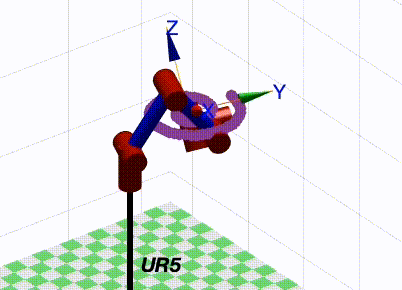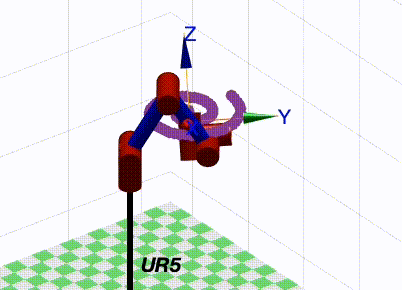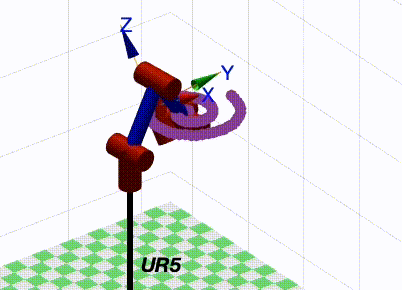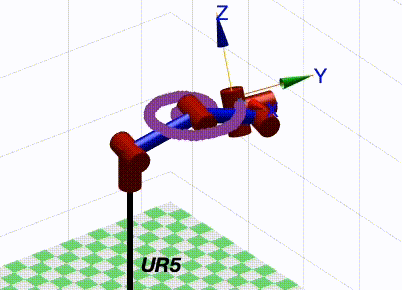
WPI Course Project 2023
Modeled an ABB IRB 910 with Newton–Euler and Lagrangian formulations, implementing gravity compensation and torque-based control in MATLAB.
WPI Course Project 2023
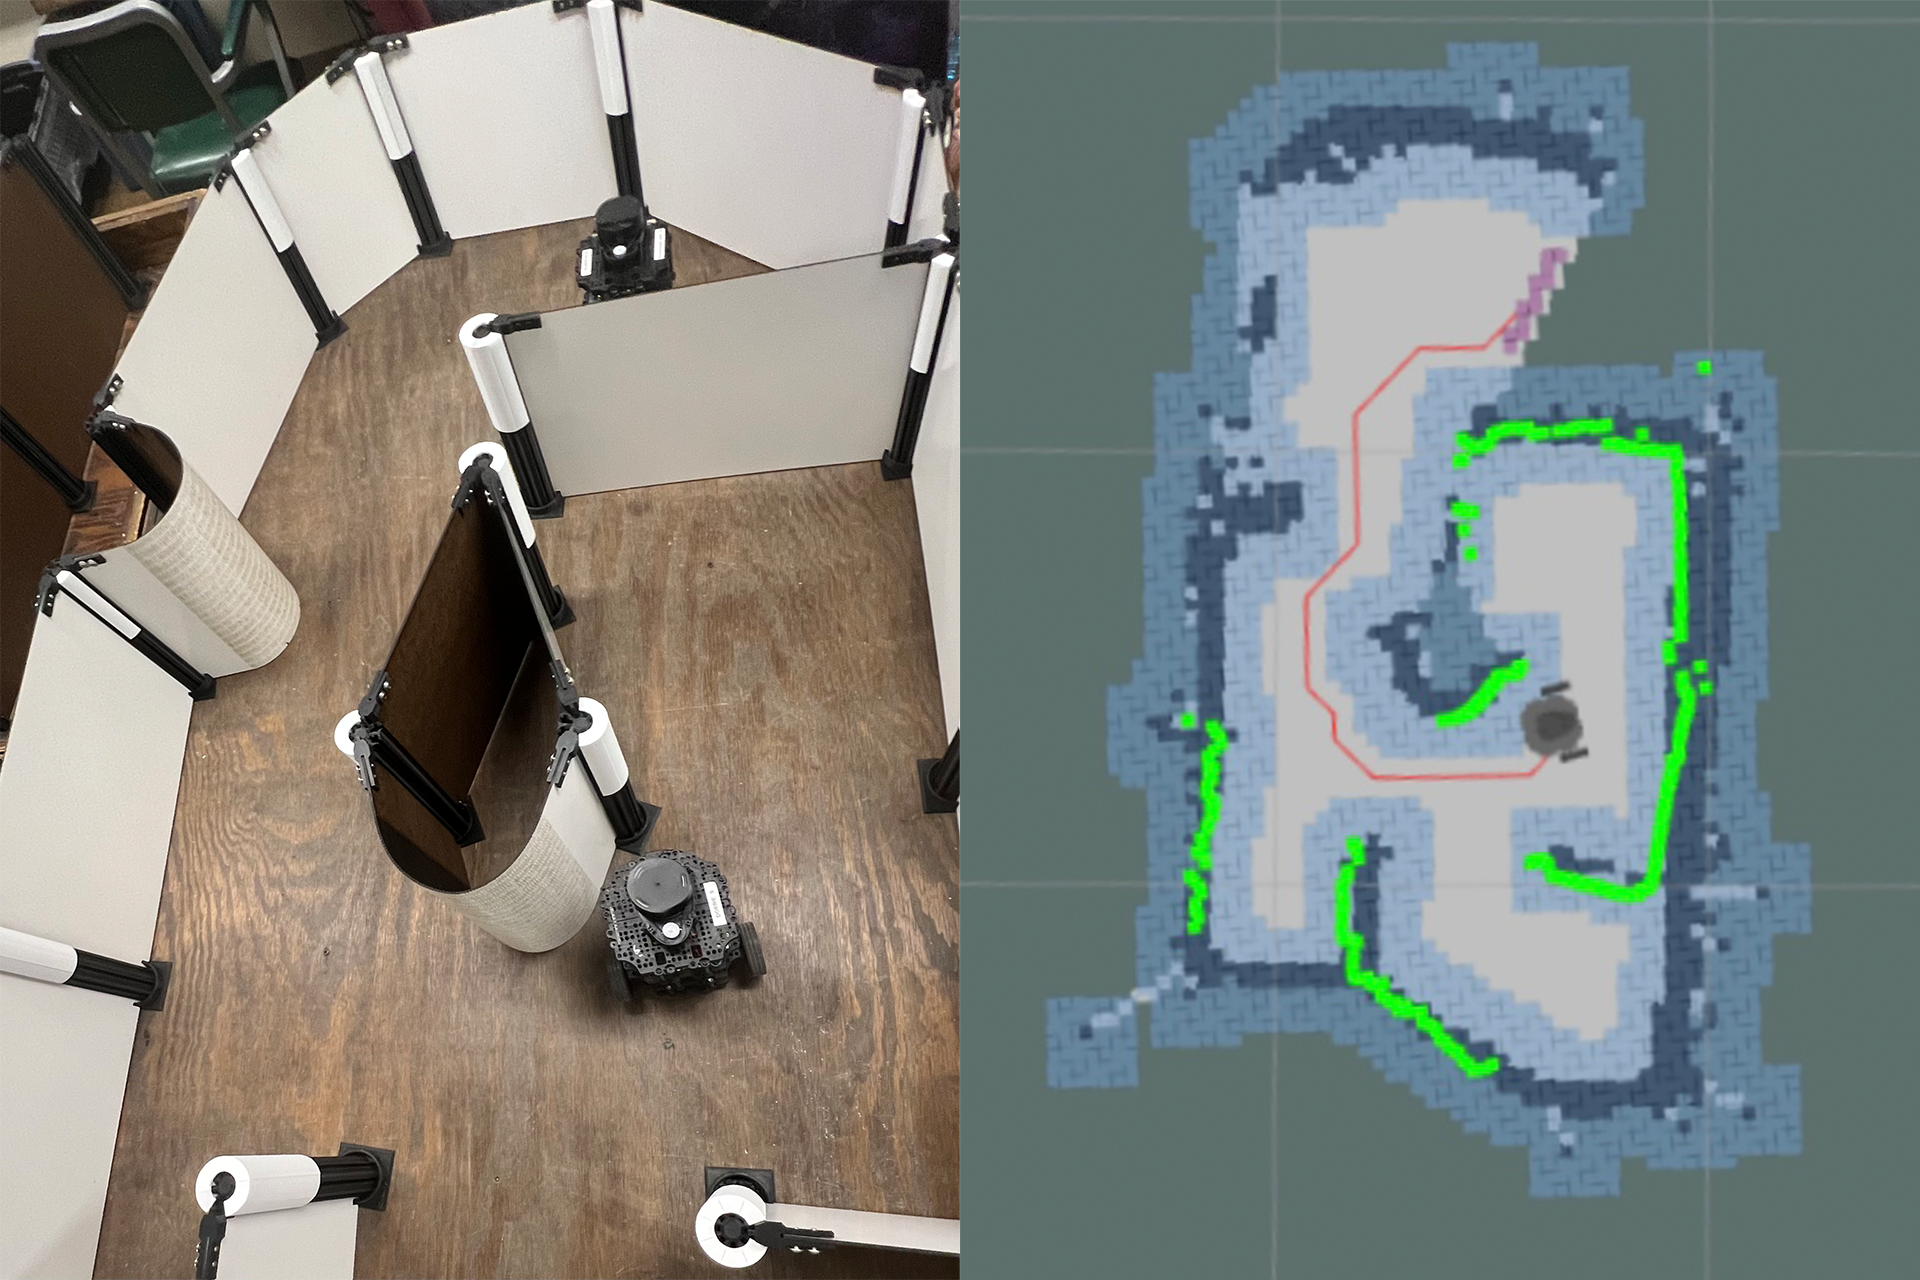
Built a TurtleBot navigation system with G-mapping, AMCL, A* and RRT planning, and Kalman-filter relocalization in ROS.
WPI Course Project 2022
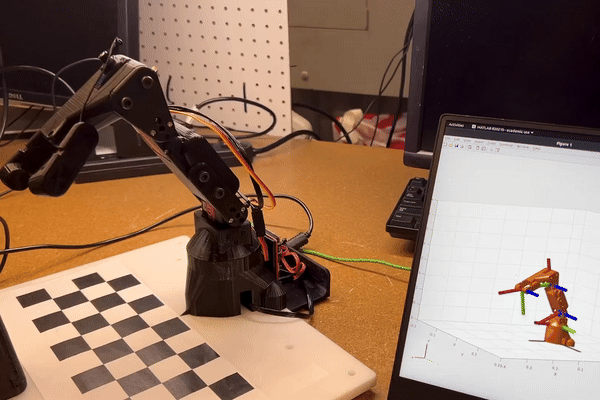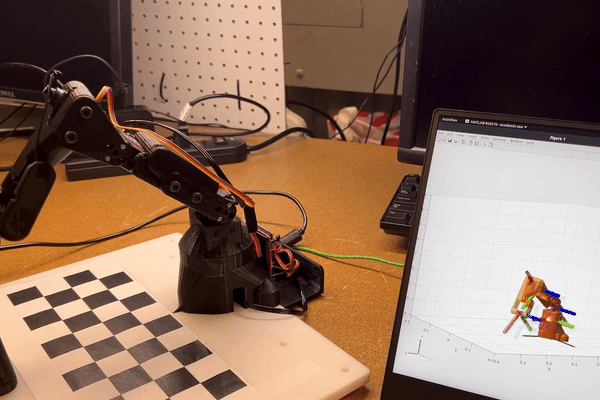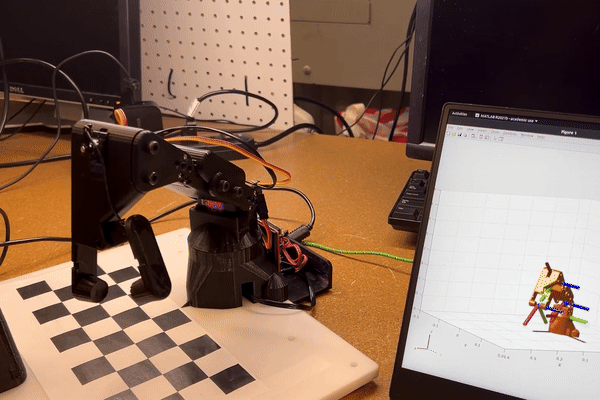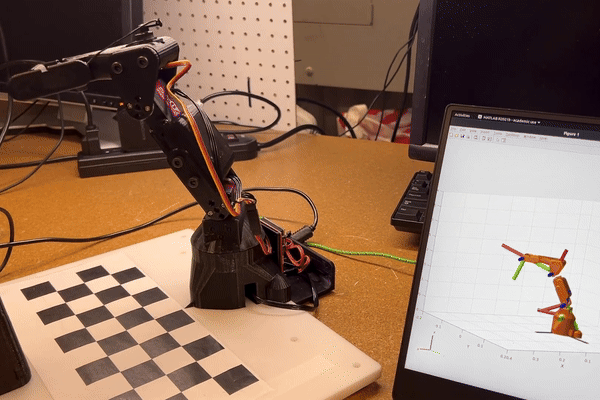
Built vision-guided object sorting with forward and inverse kinematics, smooth trajectories, and YOLOv5 and HSV-based perception.
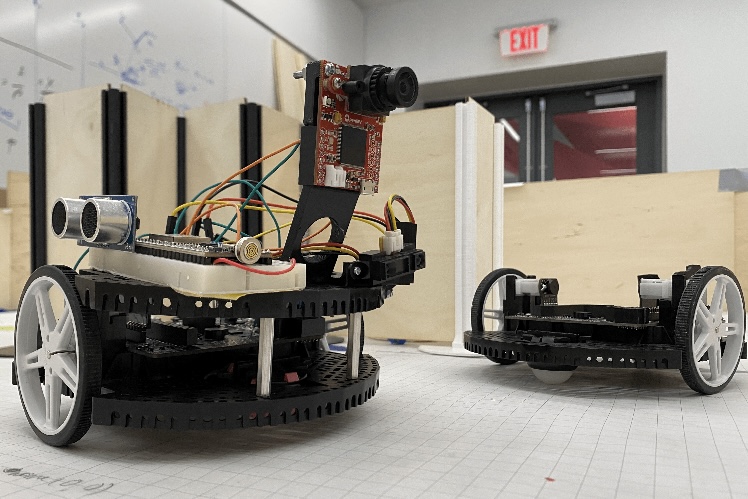
WPI Course Project 2022
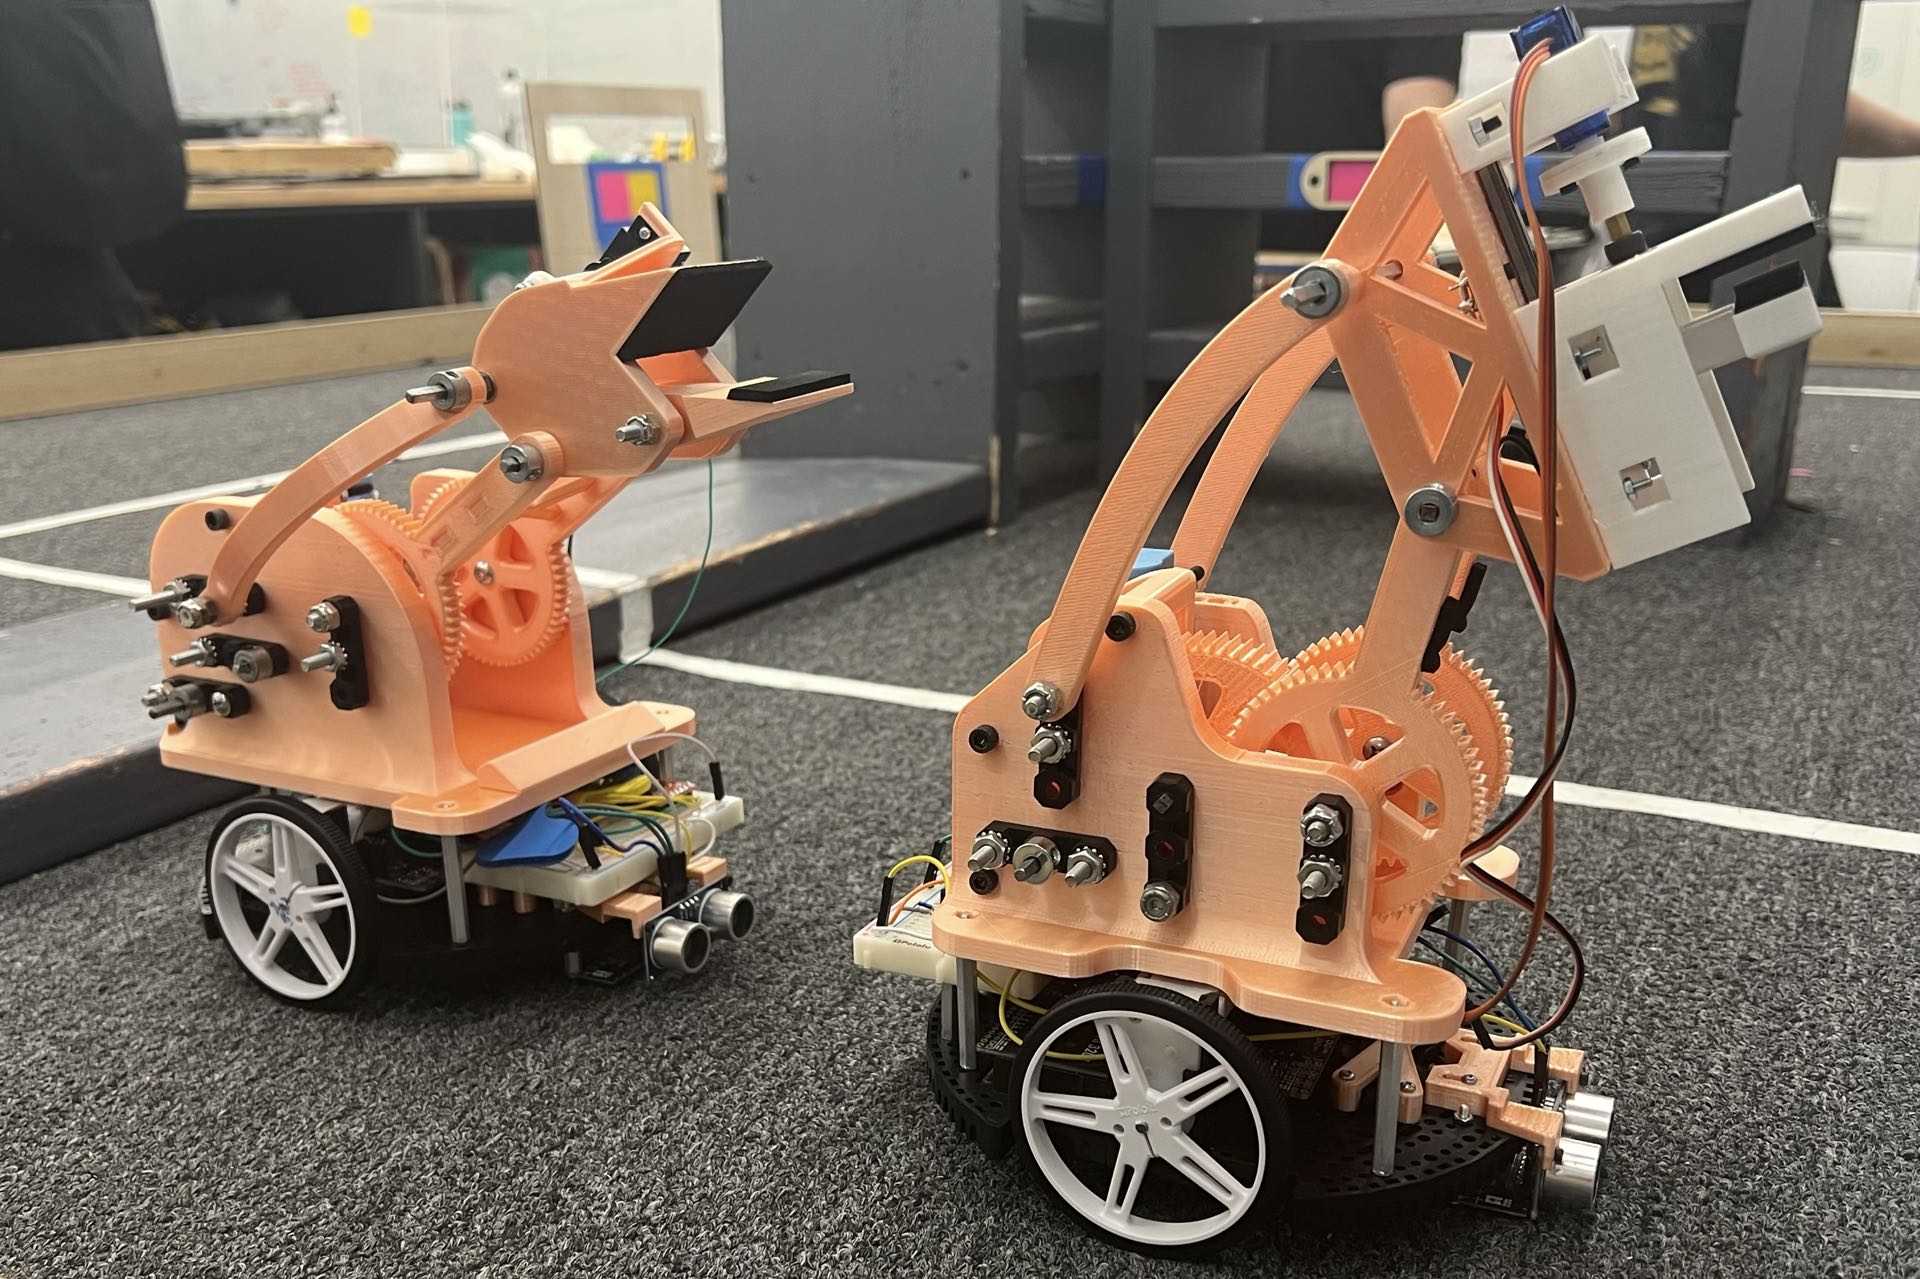
WPI Course Project 2021
M.S. in Robotics Systems Development
2024–2026
B.S. in Robotics Engineering
B.S. in Computer Science